robotic
-
Level point is used to get a reference height and transfer it on every other surface.
-
Measure a reference height on the first wall, turn the telescope with the laser pointer to the next wall. The same height is indicated on the wall.
-
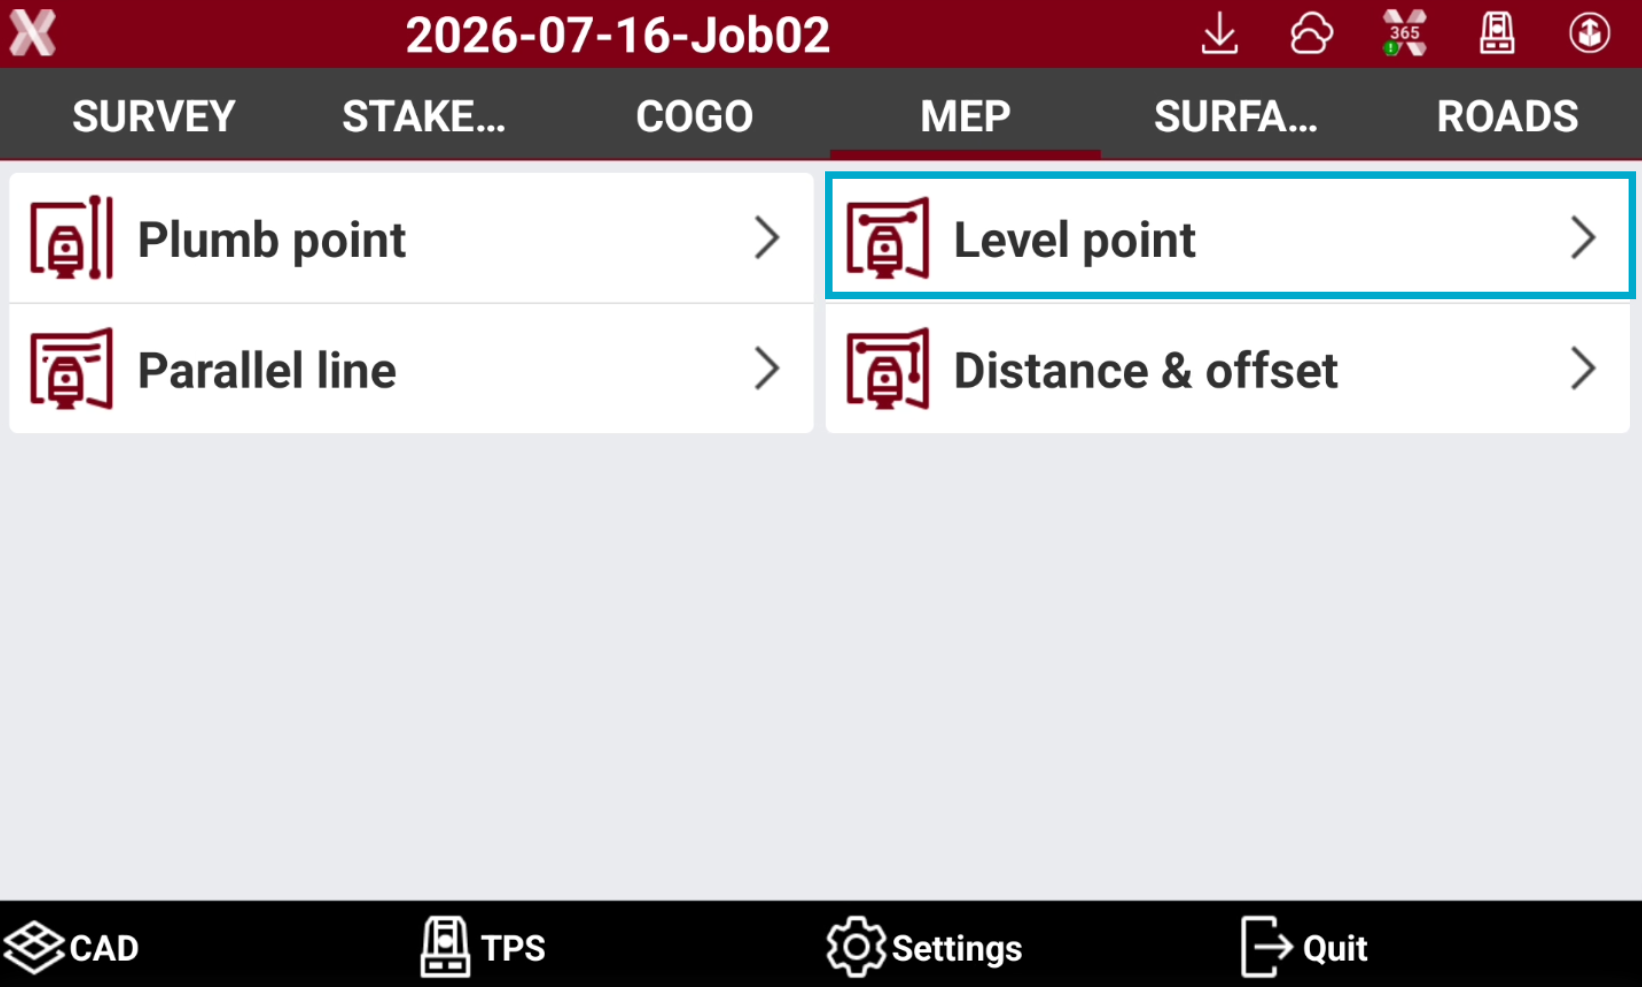
Open the MEP page.
-
Select Level point.
-
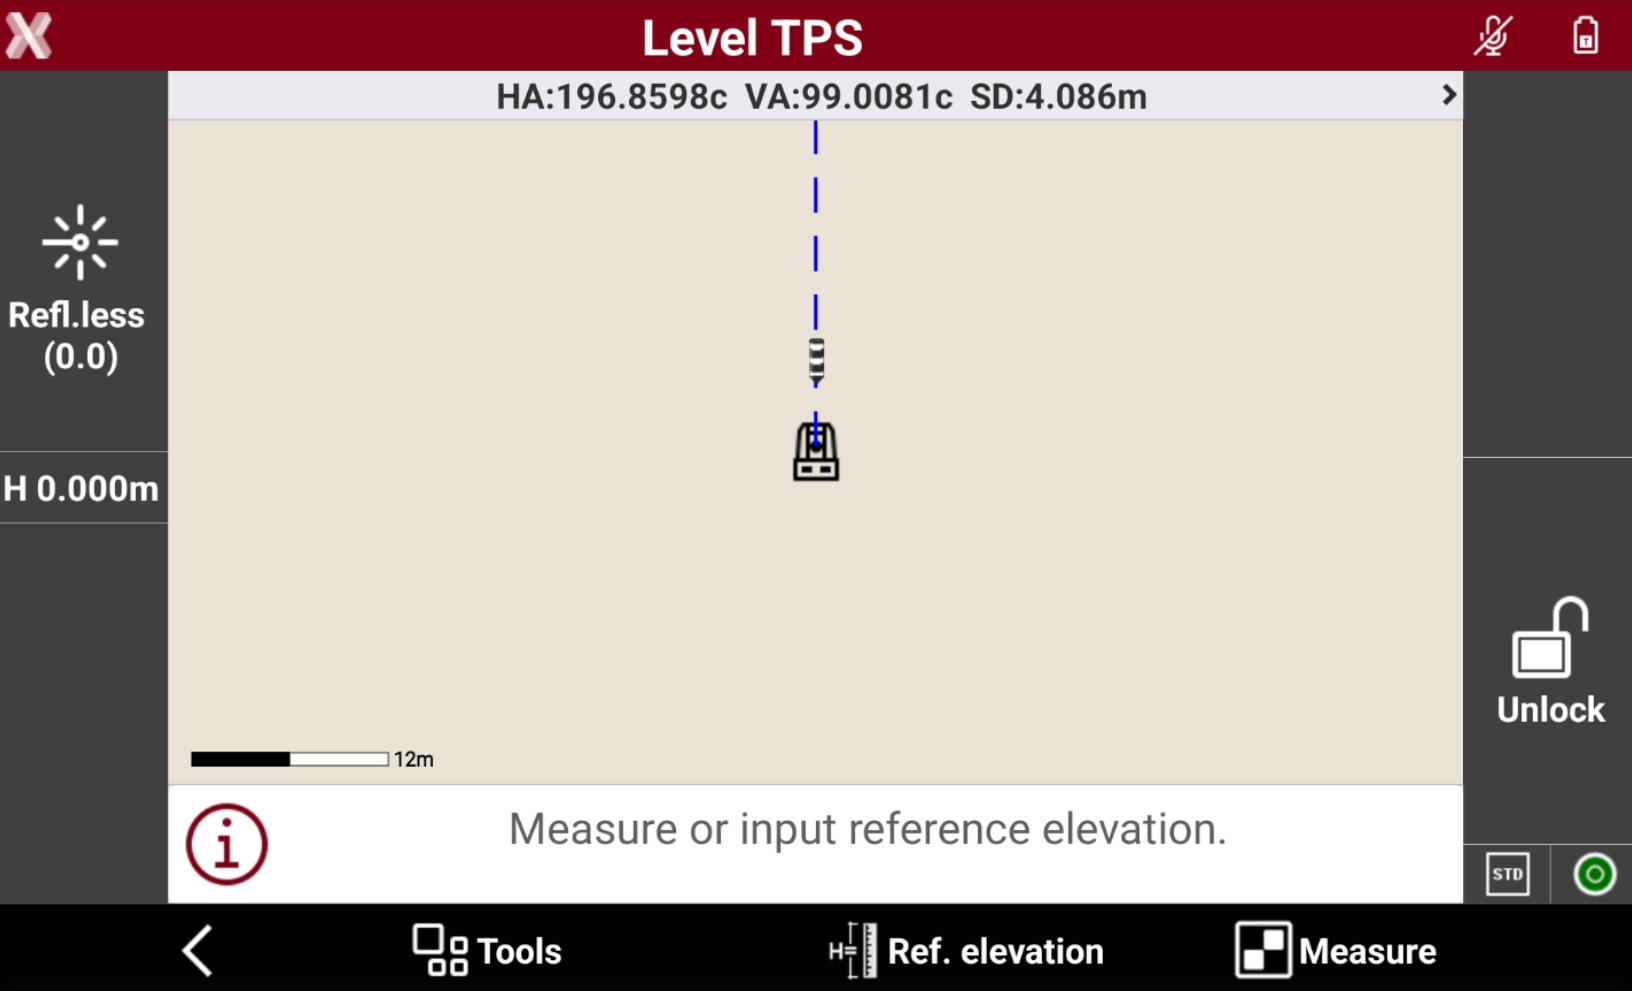
Measure or input the reference elevation.
-
To measure the reference elevation press Measure.
-
To input the reference elevation press Ref.elevation.
-
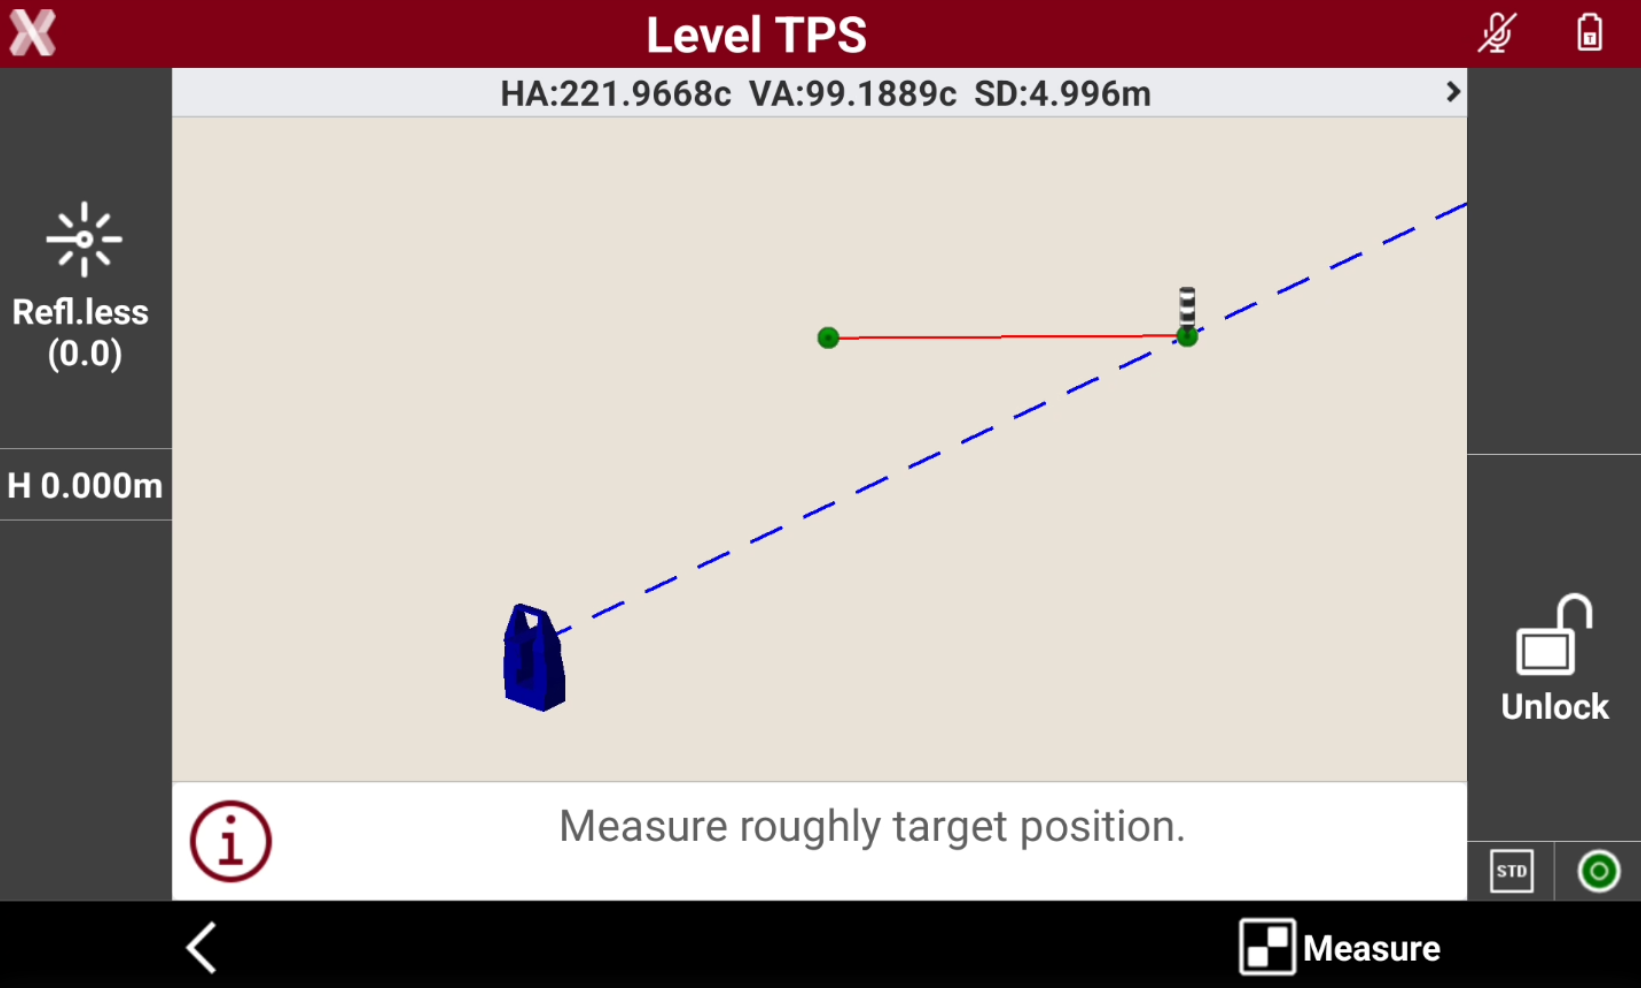
Then measure roughly the target position pressing Measure.
-
The robotic total station adjust the position to calculate display exactly the position on the wall at the same elevation.
-
The position is visualized on the wall using the instrument laser pointer.
-
Press Measure to measure a new target position to continue to transfer elevation to new positions.
If the reference point is a known point, it is possible to stakeout the known point or use the Rotate functions and then use the MEP function to transfer the height.